CAN BUS Products
CAN BUS product line: firmware libraries, secure over-CAN firmware updates, and CAN data logging.
Firmware Libraries
- Firmware libraries for UDS, ISOTP, and firmware decryption.
- Modular libraries that are not hardware-dependent and can be imported directly into any STM32 codebase.
UDS
Implements the framework for:
- ISO 14229 Unified Diagnostic Services (UDS)
- ISO 15031 On-Board Diagnostics II (OBD-II)
OBD-II is a subset of UDS oriented specifically towards emissions-testing.
ISOTP
Implements ISO 15765-2, ISO Transport Layer Protocol
The ISOTP layer allows for transmission of longer messages over fixed 8-byte CAN messages. It handles breaking the messages up into chunks and then re-assembling them into a full message.
Example Usage
In "main.c":

#include "can_isotp.h"
#include "can_uds.h"					//[OPTIONAL] if paired with "can_uds.h"

ISOTP_state_tracker ISOTP;

//Define isotp callback functions
uint8_t ISOTP_can_cb(SerBuf *isotp_frame){
	APPLICATION_CAN_transmit(isotp_frame->buffer);
	if(SUCCESS){		//Must return (0-1)
		return 0;
	}else{
		return 1;
	}
}

uint32_t ISOTP_timer_cb(void){
	return system_time_in_milliseconds;
}

static void isotp_debug_info(SerBuf *buf){	//[OPTIONAL] If debug is needed
	while (!SBUF_end_of_msg(buf)) {
		APPLICATION_print_debug(SBUF_get_char(buf));
	}
}

//Receive CAN data
APPLICATION_CAN_RX_CALLBACK{
	uint8_t CAN_FRAME[8];
	ISOTP_receive_data(&ISOTP, CAN_FRAME);
}

//Send CAN data
void APPLICATION_TX_DATA(SerBuf *buf){
	ISOTP_send_data(&ISOTP, &buf);
}

void main{
	ISOTP_init(&ISOTP);

	//ISOTP.WAIT_FC_TIMEOUT = 250;			//[OPTIONAL] Change the default ISOTP configuration settings
	//ISOTP.WAIT_CF_TIMEOUT = 250;			//			 See "can_isotp.h" for detailed definitions
	//ISOTP.STmin_local		= 0;
	//ISOTP.blocksize_local	= 0;
	//ISOTP.retry_attempts	= 5;
	//ISOTP.retry_delay		= 10;

	ISOTP_register_can_cb(&ISOTP_can_cb);
	ISOTP_register_timer_cb(&ISOTP_timer_cb);
	ISOTP_register_data_cb(&UDS_handle_message);	//Use UDS handler or  APPLICATION-specific implementation

	UDS_init();								//[OPTIONAL] if paired with "can_uds.h"

	while(1){
		[APPLICATION MAINLOOP CODE]

		ISOTP_update(&ISOTP);
	}
}
Secure Firmware Updater
Bin file → Encrypted Bin → Programmer → CAN (UDS + ISOTP) → MCU (in-chip decryption)
- Secure product updates delivered over the CAN bus.
- Includes a bootloader binary for in-chip decryption.
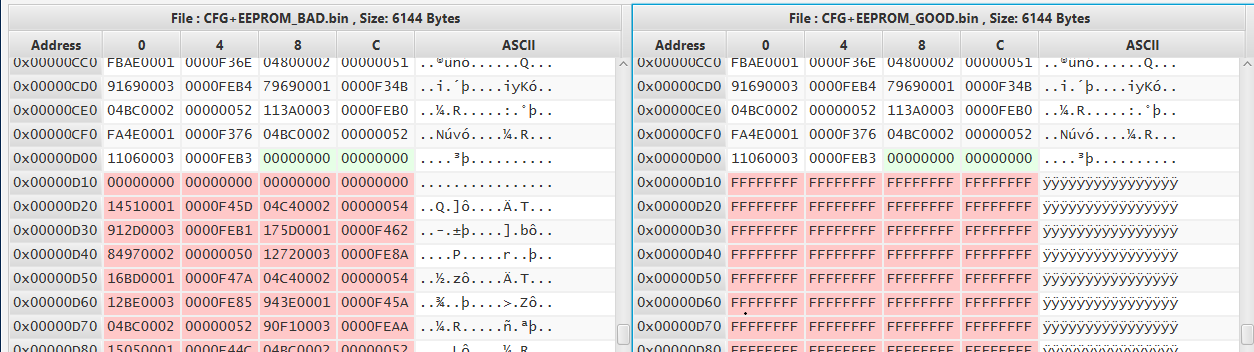
Image comparing flash writes during the bootloader development
CAN Logger
- Customizable data logging over the CAN bus using UDS.
- Small PCB with a wide input range that can be connected directly via the CAN bus.
- In-field firmware updating.
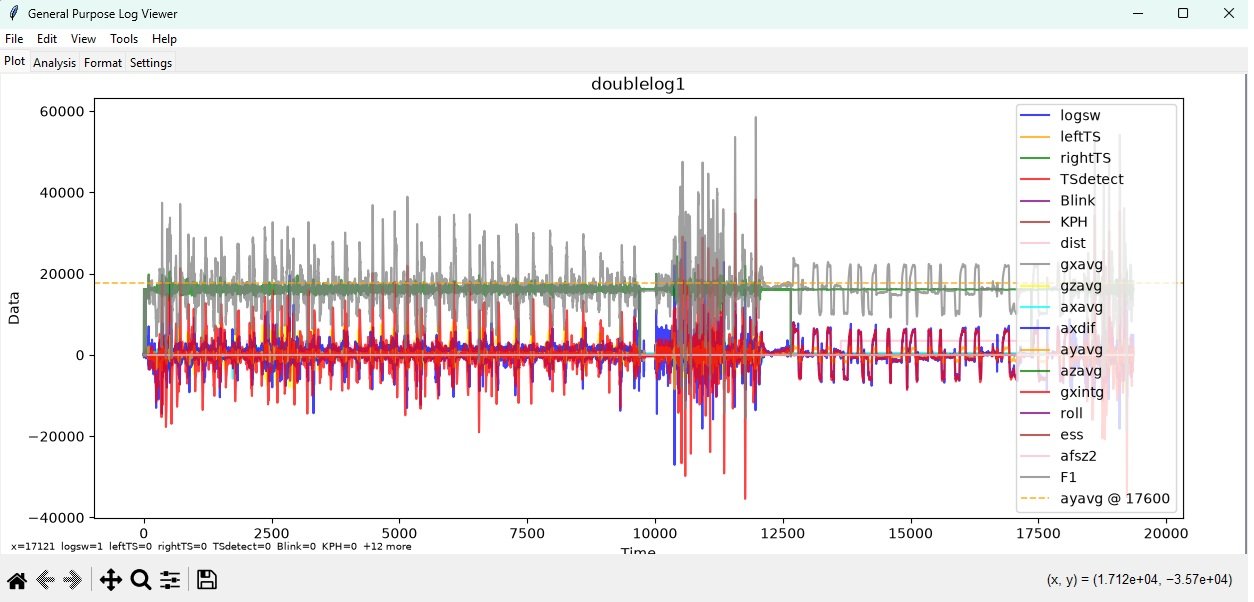
Sample logged data for MFTS product
Standalone Embedded Programmer
- Temporary solution to meet production deadlines for in-field firmware updates.